Physicl raises $10 million in seed funding to develop synthetic training data that helps robots and physical AI systems perform more reliably in real-world environments. The Paris-based startup announced the financing on Nov. 6, 2026, with Inovia Capital leading the round and U.S. Venture Partners participating.
The company also introduced Studio, a platform that allows AI researchers to create detailed 3D environments and generate training data for situations where their models struggle. The funding will support hiring and further platform development as Physicl expands its work with robotics and world-model developers.
Physicl Studio Targets Difficult Robot Training Scenarios
One of the biggest obstacles in robotics development is preparing machines for conditions that differ from their original training environments. A robot may recognize an object on an empty surface but fail when other objects partially obstruct it or changing light makes identification difficult.
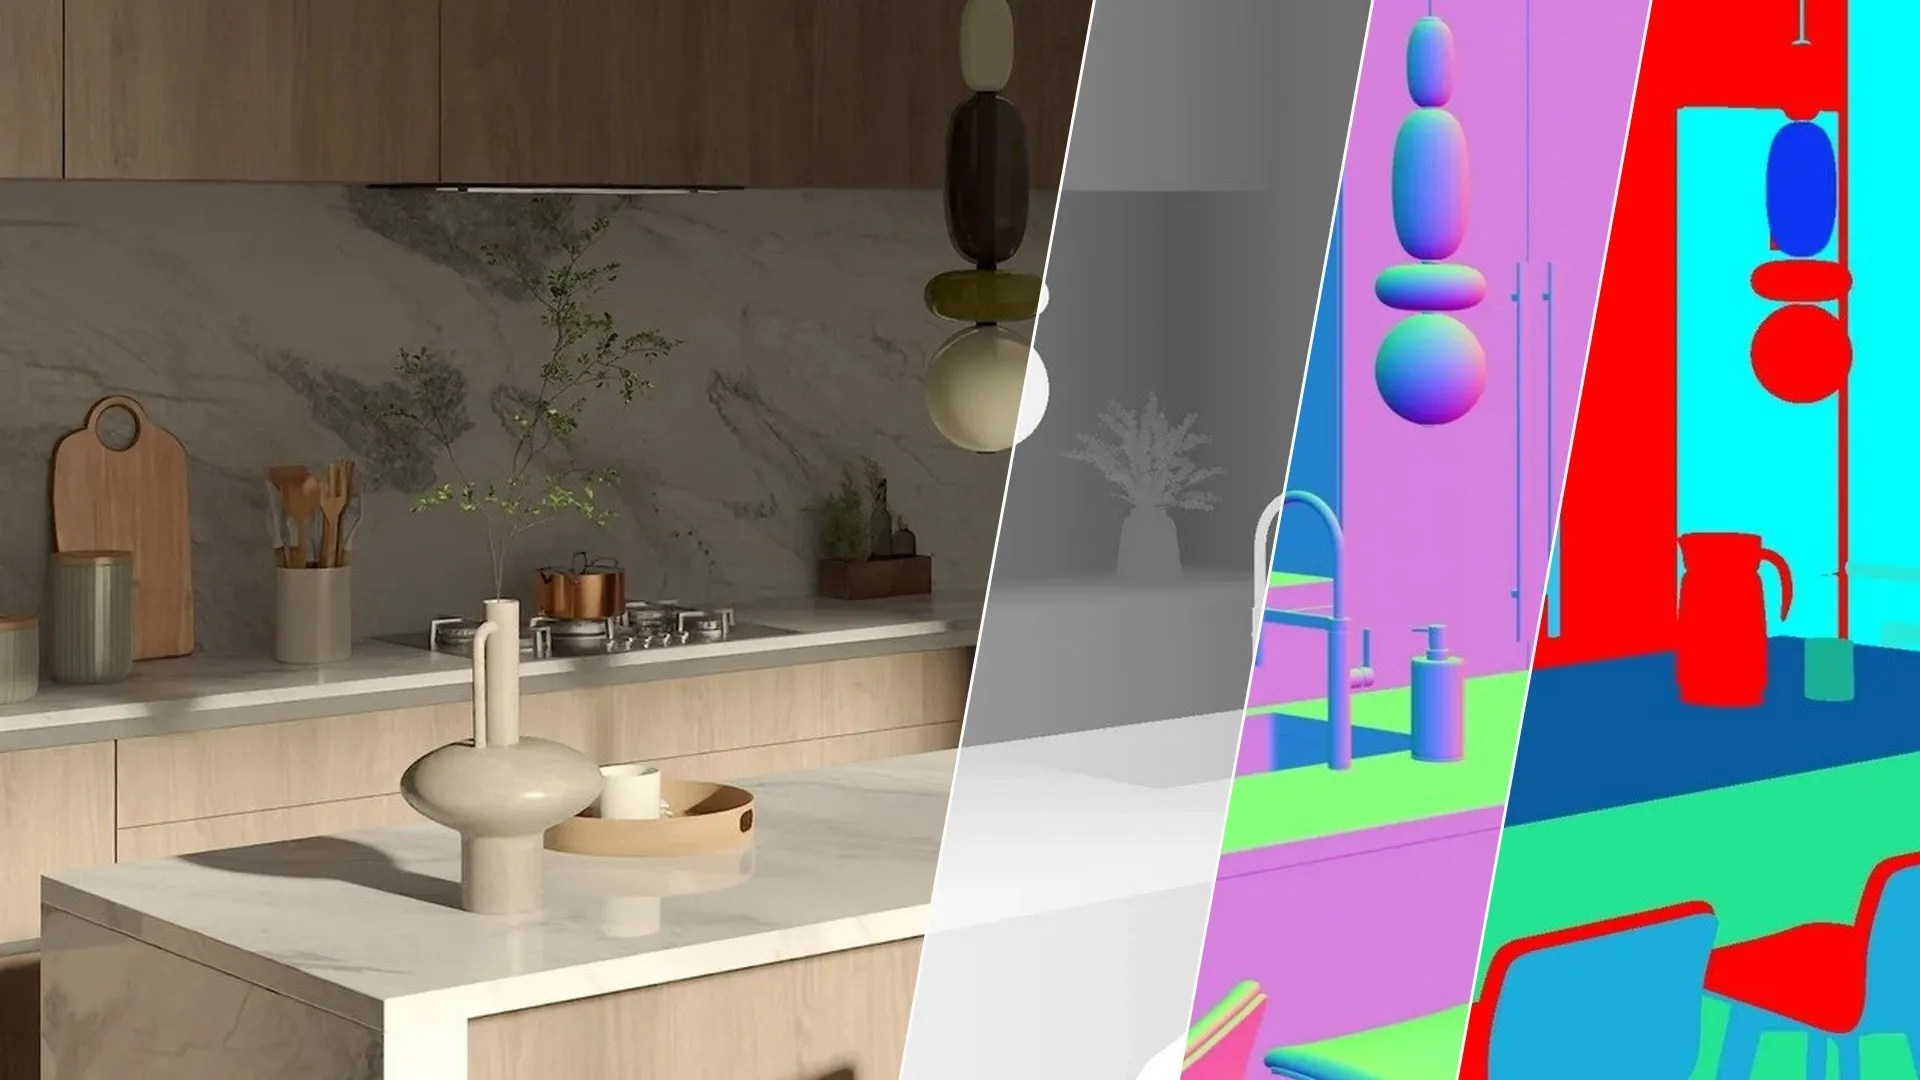
Physicl is addressing these problems through synthetic data generation. Its Studio platform provides access to more than 10,000 3D environments and 100,000 objects that researchers can combine to reproduce challenging situations.
Developers can select an existing environment or describe a scene where an AI model performs poorly. They can then adjust lighting, camera positions, object placement and other variables to produce new examples for training and evaluation.
The generated data includes ground-truth information, such as object segmentation, depth measurements and camera positions. These labels help researchers evaluate whether models correctly interpret object geometry and arrangement in simulated environments.
Why Synthetic Data Matters for Physical AI
Robotics developers commonly train models using recorded video, sensor readings and demonstrations collected from physical machines. Gathering enough examples of unusual situations can be expensive and time-consuming, particularly when researchers need to reproduce rare failures.
Simulation offers another approach by allowing developers to recreate these conditions digitally. Unlike a fixed collection of recorded examples, a configurable simulation environment can produce different arrangements of objects, viewpoints and lighting without requiring a new physical recording session.
Physicl is concentrating on post-training, where researchers attempt to correct weaknesses in models that have already undergone broader training. Rather than generating additional data indiscriminately, the company aims to produce examples that target specific errors.
The approach is part of a wider effort to improve the quality and usefulness of robotics datasets. TechAmerica previously examined how robot training data collection has become a specialized business as AI laboratories seek more information about physical interactions.
SpAItial Reports Improvements From Physical Training Data
Physicl has worked with SpAItial, a developer of AI world models that generate explorable 3D environments. The collaboration focused on improving the accuracy of reconstructing physical spaces from visual information.
According to Physicl, SpAItial reduced its model’s reconstruction error by more than half after incorporating data generated through Physicl’s library into its training process. The result shows how targeted synthetic data can address a particular model weakness, though it does not establish equivalent improvements across other robotics applications.
SpAItial’s technology includes Echo-3, a world model designed to generate three-dimensional scenes from visual inputs. Such systems aim to represent the spatial relationships AI models need to interpret or interact with physical environments.
Related research is examining how robots can learn physical relationships and anticipate changes around them. TechAmerica has also covered 1X’s robotics world model, which uses visual information to support learning and task development.
Funding Builds on Experience in 3D Technology
Physical founder and CEO Alex de Vigan previously developed 3D visualization technology through nfinite, a business serving retailers and brands. That experience involved transforming product and environmental information into detailed digital representations.
The new company is applying related technology to the different requirements of physical AI. Robotics researchers need more than visually convincing images. They also require reliable information about object dimensions, spatial relationships, materials and simulated conditions.
Physicl says its platform is already being used in work involving AI laboratories and technology organizations, including Meta, World Labs, Epic Games and SpAItial. The company has not disclosed detailed commercial terms for those relationships.
The $10 million seed round will help Physicl expand its team and develop the tools needed to generate targeted datasets. The company is positioning Studio as a system researchers can use repeatedly as they identify additional model failures.
Simulations Still Face Real-World Limitations
Generating realistic digital environments does not automatically guarantee that a robot will perform correctly outside a simulation. Differences in materials, sensor behavior, contact forces and other physical conditions can affect how learned capabilities transfer to actual machines.
Developers must therefore evaluate whether synthetic training data produces measurable improvements under real operating conditions. Results from a particular reconstruction model cannot be assumed to apply equally to robot manipulation, navigation or other tasks.
This challenge also affects efforts to develop safer autonomous machines. As TechAmerica reported in its coverage of simulation-based robot safety testing, researchers are developing ways to examine how AI-powered robots behave before placing them in environments shared with people.
Studio is currently in private beta, with access available through requests to Physicl. The company’s next challenge is demonstrating that its targeted training environments can consistently improve performance across different physical AI models, beyond the individual results reported by early collaborators.